Machine Learning
The Math of a Curriculum That Backfired: How Teaching a Robot Dog the Basics Stopped It Walking
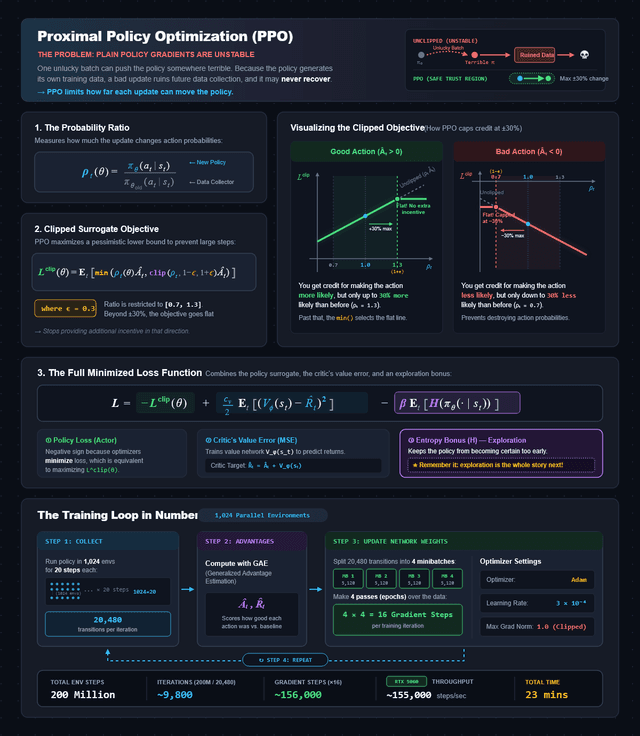
Part 2 of a series on training a simulated Unitree Go1 quadruped with reinforcement learning. Everything here comes from runs on a single RTX 5060 (8 GB) with MuJoCo Playground, MJX/Warp and Brax PPO. Part 1 covers the MDP, the reward and PPO. We wanted a robot that walks and is hard to knock over. […]
Read Main Article→